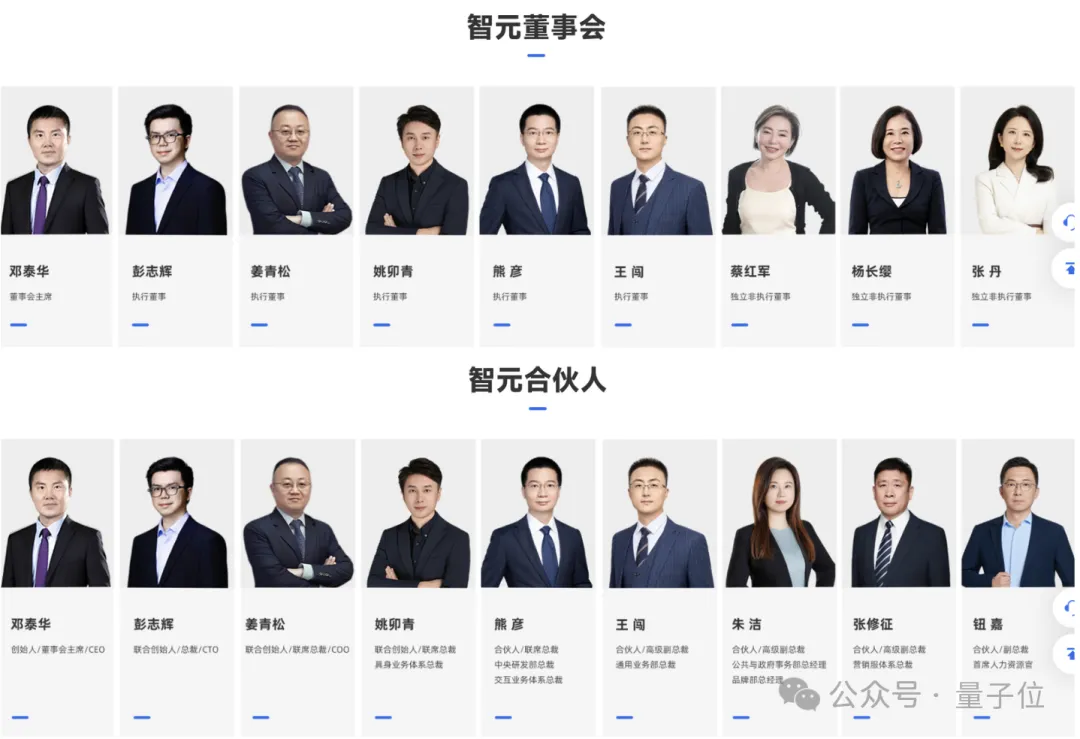
智元下架了首席科学家罗剑岚
Ranking
No observed public metrics; popularity remains neutral/archived.
Merged summary
TL;DR - Chinese humanoid-robot maker AgiBot (智元) has quietly removed chief scientist Luo Jianlan (罗剑岚) from its official partner/leadership page, suggesting he has left after ~16 months, just weeks after the company confirmed it started a Hong Kong IPO process. Neither party has confirmed the change, but it signals possible turbulence in AgiBot's core embodied-AI research leadership.
- Luo joined AgiBot in April 2025 as chief scientist and founded its Embodied Intelligence Research Center; he later became partner/SVP. His personal site and X bio now list only his Shanghai Innovation Institute assistant professorship, with AgiBot references removed.
- Academic background: UC Berkeley PhD (advisors Pieter Abbeel, Alice Agogino), Google X researcher with Stefan Schaal, then BAIR postdoc under Sergey Levine; ~8,449 Google Scholar citations.
- Key prior work: SERL (a reusable real-robot RL stack covering algorithms, data collection, reward design, and control) and HIL-SERL, which adds brief human interventions near failure so a few corrective samples replace large demonstration datasets.
- At AgiBot he drove real-robot RL into industrial assembly, built SOP/LWD pipelines linking deployment, data return, and model updates, and worked on τ0-WM world models for pre-execution prediction/evaluation — plus VLA work he publicized on X only last week.
Sources (1)
智元下架了首席科学家罗剑岚
TL;DR - Chinese humanoid-robot maker AgiBot (智元) has quietly removed chief scientist Luo Jianlan (罗剑岚) from its official partner/leadership page, suggesting he has left after ~16 months, just weeks after the company confirmed it started a Hong Kong IPO process. Neither party has confirmed the change, but it signals possible turbulence in AgiBot's core embodied-AI research leadership.
- Luo joined AgiBot in April 2025 as chief scientist and founded its Embodied Intelligence Research Center; he later became partner/SVP. His personal site and X bio now list only his Shanghai Innovation Institute assistant professorship, with AgiBot references removed.
- Academic background: UC Berkeley PhD (advisors Pieter Abbeel, Alice Agogino), Google X researcher with Stefan Schaal, then BAIR postdoc under Sergey Levine; ~8,449 Google Scholar citations.
- Key prior work: SERL (a reusable real-robot RL stack covering algorithms, data collection, reward design, and control) and HIL-SERL, which adds brief human interventions near failure so a few corrective samples replace large demonstration datasets.
- At AgiBot he drove real-robot RL into industrial assembly, built SOP/LWD pipelines linking deployment, data return, and model updates, and worked on τ0-WM world models for pre-execution prediction/evaluation — plus VLA work he publicized on X only last week.