RT by @ylecun: With GAIA-4 we've been able to deploy world models for safety critical simulation…
Ranking
No observed public metrics; popularity remains neutral/archived.
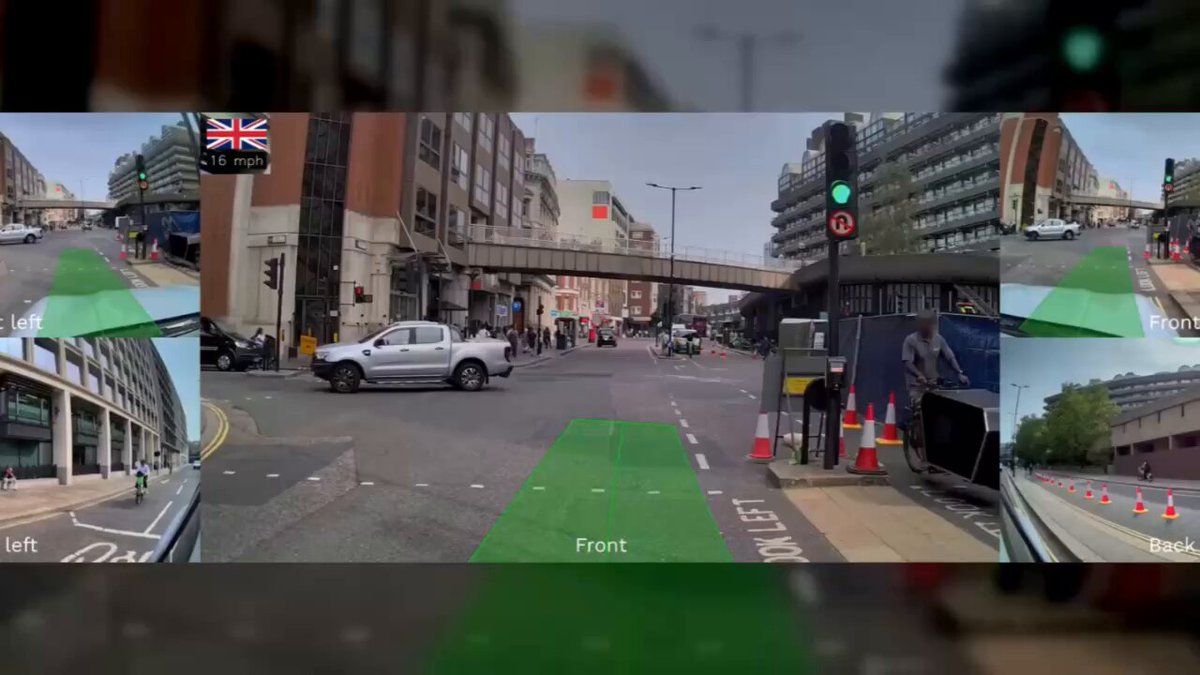
Merged summary
TL;DR - A Wayve announcement (retweeted by Yann LeCun) that its GAIA-4 world model is now deployed for safety-critical driving simulation, showcasing closed-loop counter-factual replays of cyclist and pedestrian interactions. It signals world models moving from research demos into production validation tooling for autonomous driving.
- GAIA-4 is presented as a deployed generative world model used for safety-critical simulation, not just an offline research artifact.
- Demonstrations focus on counter-factual replay: re-running recorded scenarios with altered agent behavior to probe vulnerable-road-user (cyclist, pedestrian) interactions.
- Simulation runs closed-loop, meaning the driving policy's actions feed back into the generated scene rather than replaying a fixed log.
- Content is thin (a short promotional post plus video links); no benchmarks, fidelity metrics, or architecture details are given — the linked Wayve blog is the substantive source.
Sources (1)
RT by @ylecun: With GAIA-4 we've been able to deploy world models for safety critical simulation…
TL;DR - A Wayve announcement (retweeted by Yann LeCun) that its GAIA-4 world model is now deployed for safety-critical driving simulation, showcasing closed-loop counter-factual replays of cyclist and pedestrian interactions. It signals world models moving from research demos into production validation tooling for autonomous driving.
- GAIA-4 is presented as a deployed generative world model used for safety-critical simulation, not just an offline research artifact.
- Demonstrations focus on counter-factual replay: re-running recorded scenarios with altered agent behavior to probe vulnerable-road-user (cyclist, pedestrian) interactions.
- Simulation runs closed-loop, meaning the driving policy's actions feed back into the generated scene rather than replaying a fixed log.
- Content is thin (a short promotional post plus video links); no benchmarks, fidelity metrics, or architecture details are given — the linked Wayve blog is the substantive source.