π0引用的中国团队,又出手了:世界仿真器新作发布
Ranking
Overall
71
Content
80
Popularity
N/A
No observed public metrics; popularity remains neutral/archived.
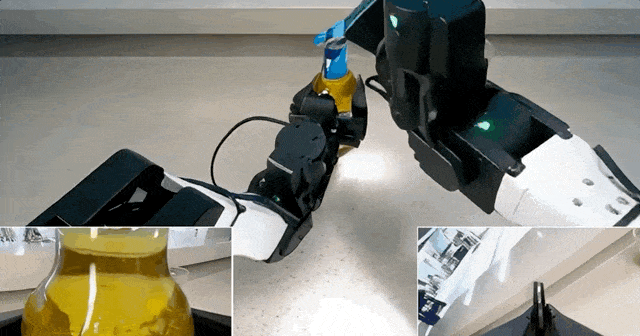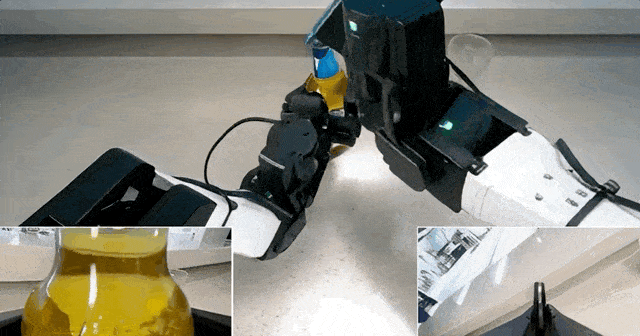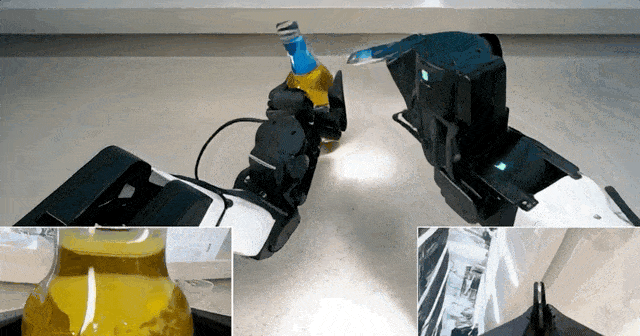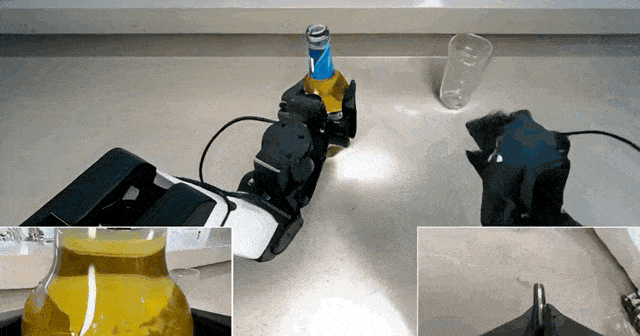
Merged summary
TL;DR - Current Robotics unveiled CurrentWorld-0, an interactive world simulator for evaluating and improving robot policies across different embodiments. It combines action-conditioned simulation, synchronized multi-view generation, and force/tactile prediction to model failures more faithfully before real-world deployment.
- Preserves each robot’s native action space while modeling consistent environmental physics across fixed-arm, mobile, and humanoid platforms.
- Prevents video priors from “correcting” failed actions into successful outcomes, improving policy-evaluation fidelity.
- Generates synchronized camera views and predicts force/tactile feedback for contact-sensitive tasks.
- Supports human takeover, state saving, and rollback to collect corrective trajectories for policy post-training.
Sources (1)
π0引用的中国团队,又出手了:世界仿真器新作发布
Public signals
N/A
TL;DR - Current Robotics unveiled CurrentWorld-0, an interactive world simulator for evaluating and improving robot policies across different embodiments. It combines action-conditioned simulation, synchronized multi-view generation, and force/tactile prediction to model failures more faithfully before real-world deployment.
- Preserves each robot’s native action space while modeling consistent environmental physics across fixed-arm, mobile, and humanoid platforms.
- Prevents video priors from “correcting” failed actions into successful outcomes, improving policy-evaluation fidelity.
- Generates synchronized camera views and predicts force/tactile feedback for contact-sensitive tasks.
- Supports human takeover, state saving, and rollback to collect corrective trajectories for policy post-training.