GPT-6 Astra开进机器人身体!清华联手无问芯穹等开源RPent
Ranking
Observed public metrics from 1 member.
Merged summary
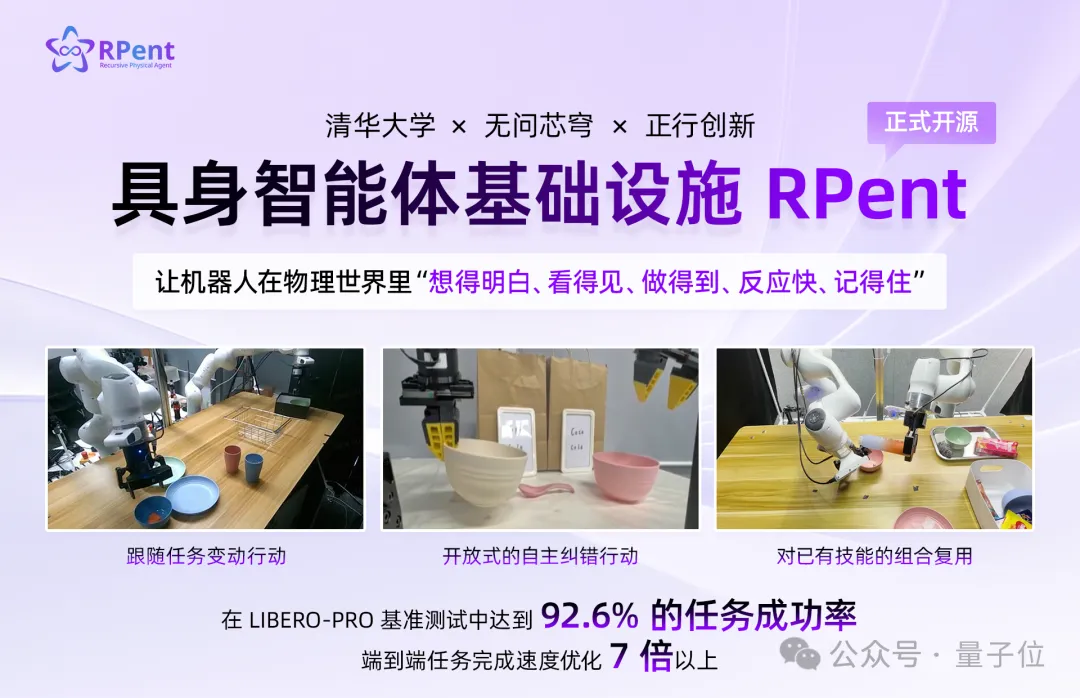
TL;DR - Tsinghua University, Infinigence AI, and Zhengxing Innovation open-sourced RPent, a modular infrastructure framework that combines general-purpose LLM planning with specialized robotic-control models, tools, and memory. It enables robots to adapt and reuse validated workflows, reporting 92.6% success on LIBERO-PRO and over 7× faster execution with Flash Mode.
- RPent separates task planning from precise control: foundation models interpret goals and orchestrate tools, while VLA, WAM, and programmatic skills execute physical actions.
- Its closed loop observes outcomes, replans after errors or environmental changes, and stores verified experiences as reusable task cards rather than fixed coordinates.
- Flash Mode executes task cards without repeatedly invoking the LLM, reducing average LIBERO Object completion time from 283.6 to 40.9 seconds with a 3.5-point success-rate decrease.
- Standardized MCP, RPC, and hardware interfaces support multiple simulators and robots, including LIBERO-PRO, RoboCasa, RoboTwin, Franka, dual-arm Franka, YAM, and SO101.
Sources (1)
GPT-6 Astra开进机器人身体!清华联手无问芯穹等开源RPent
TL;DR - Tsinghua University, Infinigence AI, and Zhengxing Innovation open-sourced RPent, a modular infrastructure framework that combines general-purpose LLM planning with specialized robotic-control models, tools, and memory. It enables robots to adapt and reuse validated workflows, reporting 92.6% success on LIBERO-PRO and over 7× faster execution with Flash Mode.
- RPent separates task planning from precise control: foundation models interpret goals and orchestrate tools, while VLA, WAM, and programmatic skills execute physical actions.
- Its closed loop observes outcomes, replans after errors or environmental changes, and stores verified experiences as reusable task cards rather than fixed coordinates.
- Flash Mode executes task cards without repeatedly invoking the LLM, reducing average LIBERO Object completion time from 283.6 to 40.9 seconds with a 3.5-point success-rate decrease.
- Standardized MCP, RPC, and hardware interfaces support multiple simulators and robots, including LIBERO-PRO, RoboCasa, RoboTwin, Franka, dual-arm Franka, YAM, and SO101.