华为大模型双子星联手创业,要找物理世界的Scaling Law
Ranking
No observed public metrics; popularity remains neutral/archived.
Merged summary
TL;DR - Physical AI startup Xirang Kaiwu, founded by two former Huawei foundation-model leaders, raised several hundred million yuan to develop a Large Physics Model (LPM) for transferable robot intelligence. The company is testing whether physical-world capabilities can scale with data and compute as language-model capabilities do.
- Its LPM uses a Unified Autoregressive Transformer to model states, actions, next states, and long-horizon decisions, with diffusion optionally rendering predicted futures as video.
- Training will combine internet and egocentric video, demonstrations, simulations, public robot trajectories, and real-world feedback in a reinforcement-learning data loop.
- The architecture unifies visual, action, tactile, and force inputs, aiming to transfer learned physical knowledge across robot bodies, tasks, and environments.
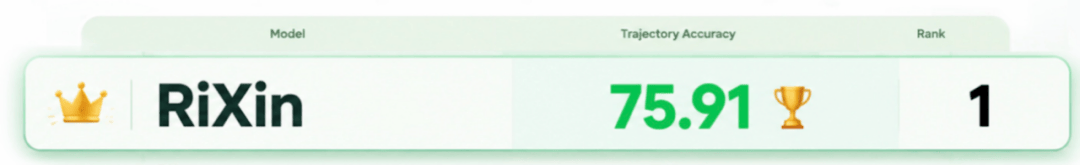
- The company reports early benchmark and scaling signals, but has not yet established a physical-world scaling law; its XIRRA v0.1 model is planned for later in 2026.
Sources (1)
华为大模型双子星联手创业,要找物理世界的Scaling Law
TL;DR - Physical AI startup Xirang Kaiwu, founded by two former Huawei foundation-model leaders, raised several hundred million yuan to develop a Large Physics Model (LPM) for transferable robot intelligence. The company is testing whether physical-world capabilities can scale with data and compute as language-model capabilities do.
- Its LPM uses a Unified Autoregressive Transformer to model states, actions, next states, and long-horizon decisions, with diffusion optionally rendering predicted futures as video.
- Training will combine internet and egocentric video, demonstrations, simulations, public robot trajectories, and real-world feedback in a reinforcement-learning data loop.
- The architecture unifies visual, action, tactile, and force inputs, aiming to transfer learned physical knowledge across robot bodies, tasks, and environments.
- The company reports early benchmark and scaling signals, but has not yet established a physical-world scaling law; its XIRRA v0.1 model is planned for later in 2026.