索辰科技加码世界模型,与战略投资企业美梦空间联合发布具身模型与物理测评标准
Ranking
No observed public metrics; popularity remains neutral/archived.
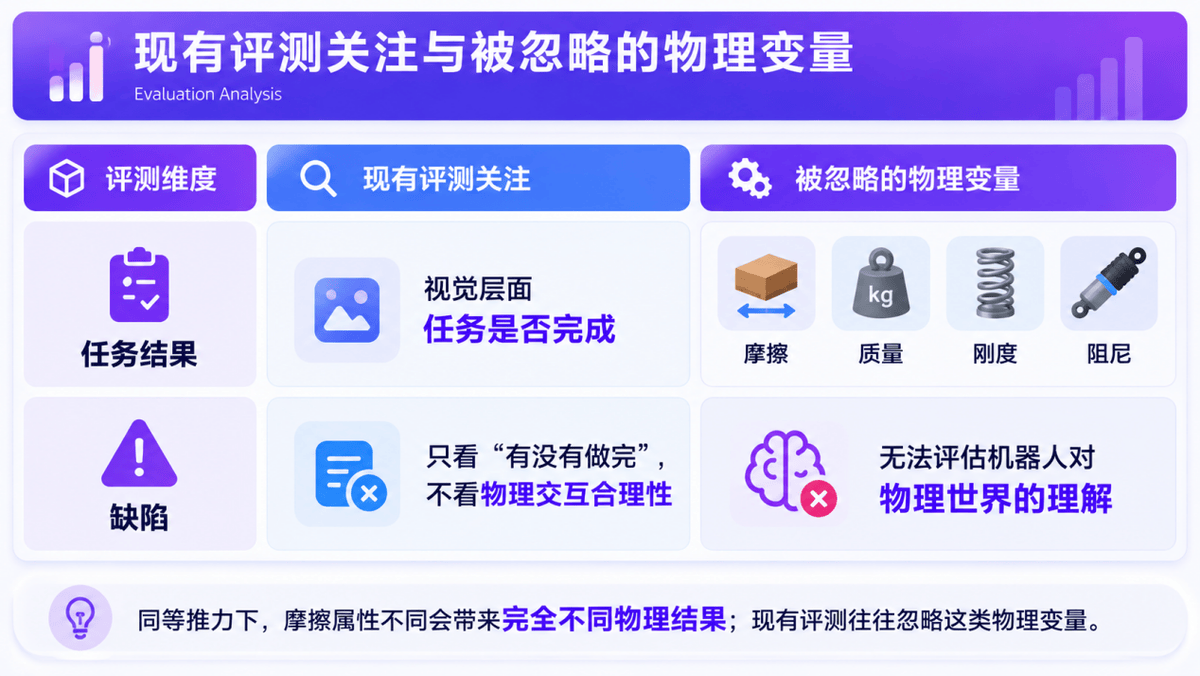
Merged summary
TL;DR - Memo, backed by Suochen Technology, launched Physical-WAM, a world-action model designed to infer physical properties and adapt robot actions, alongside the open-source RoboTwin-Phys benchmark. The pair targets a key weakness of vision-language-action models: poor robustness when friction, mass, balance, or other physical conditions change.
- Physical-WAM uses physical tokens to represent properties such as friction, weight, center of gravity, and contact state.
- Its PhysLens, PhysDream, and PhysAct modules form a feedback loop for physical perception, outcome prediction, action generation, and real-time correction.
- RoboTwin-Phys evaluates physical-property inference and task robustness across 13 perturbation types spanning object, contact, damping, environment, and camera variables.
- The benchmark provides ground-truth physics, contact-force logs, kinematic data, failure timelines, paired seeded tests, code, datasets, and a public leaderboard.
Sources (1)
索辰科技加码世界模型,与战略投资企业美梦空间联合发布具身模型与物理测评标准
TL;DR - Memo, backed by Suochen Technology, launched Physical-WAM, a world-action model designed to infer physical properties and adapt robot actions, alongside the open-source RoboTwin-Phys benchmark. The pair targets a key weakness of vision-language-action models: poor robustness when friction, mass, balance, or other physical conditions change.
- Physical-WAM uses physical tokens to represent properties such as friction, weight, center of gravity, and contact state.
- Its PhysLens, PhysDream, and PhysAct modules form a feedback loop for physical perception, outcome prediction, action generation, and real-time correction.
- RoboTwin-Phys evaluates physical-property inference and task robustness across 13 perturbation types spanning object, contact, damping, environment, and camera variables.
- The benchmark provides ground-truth physics, contact-force logs, kinematic data, failure timelines, paired seeded tests, code, datasets, and a public leaderboard.