从模型到生产力:星海图与产业朋友圈共探具身智能的下一站
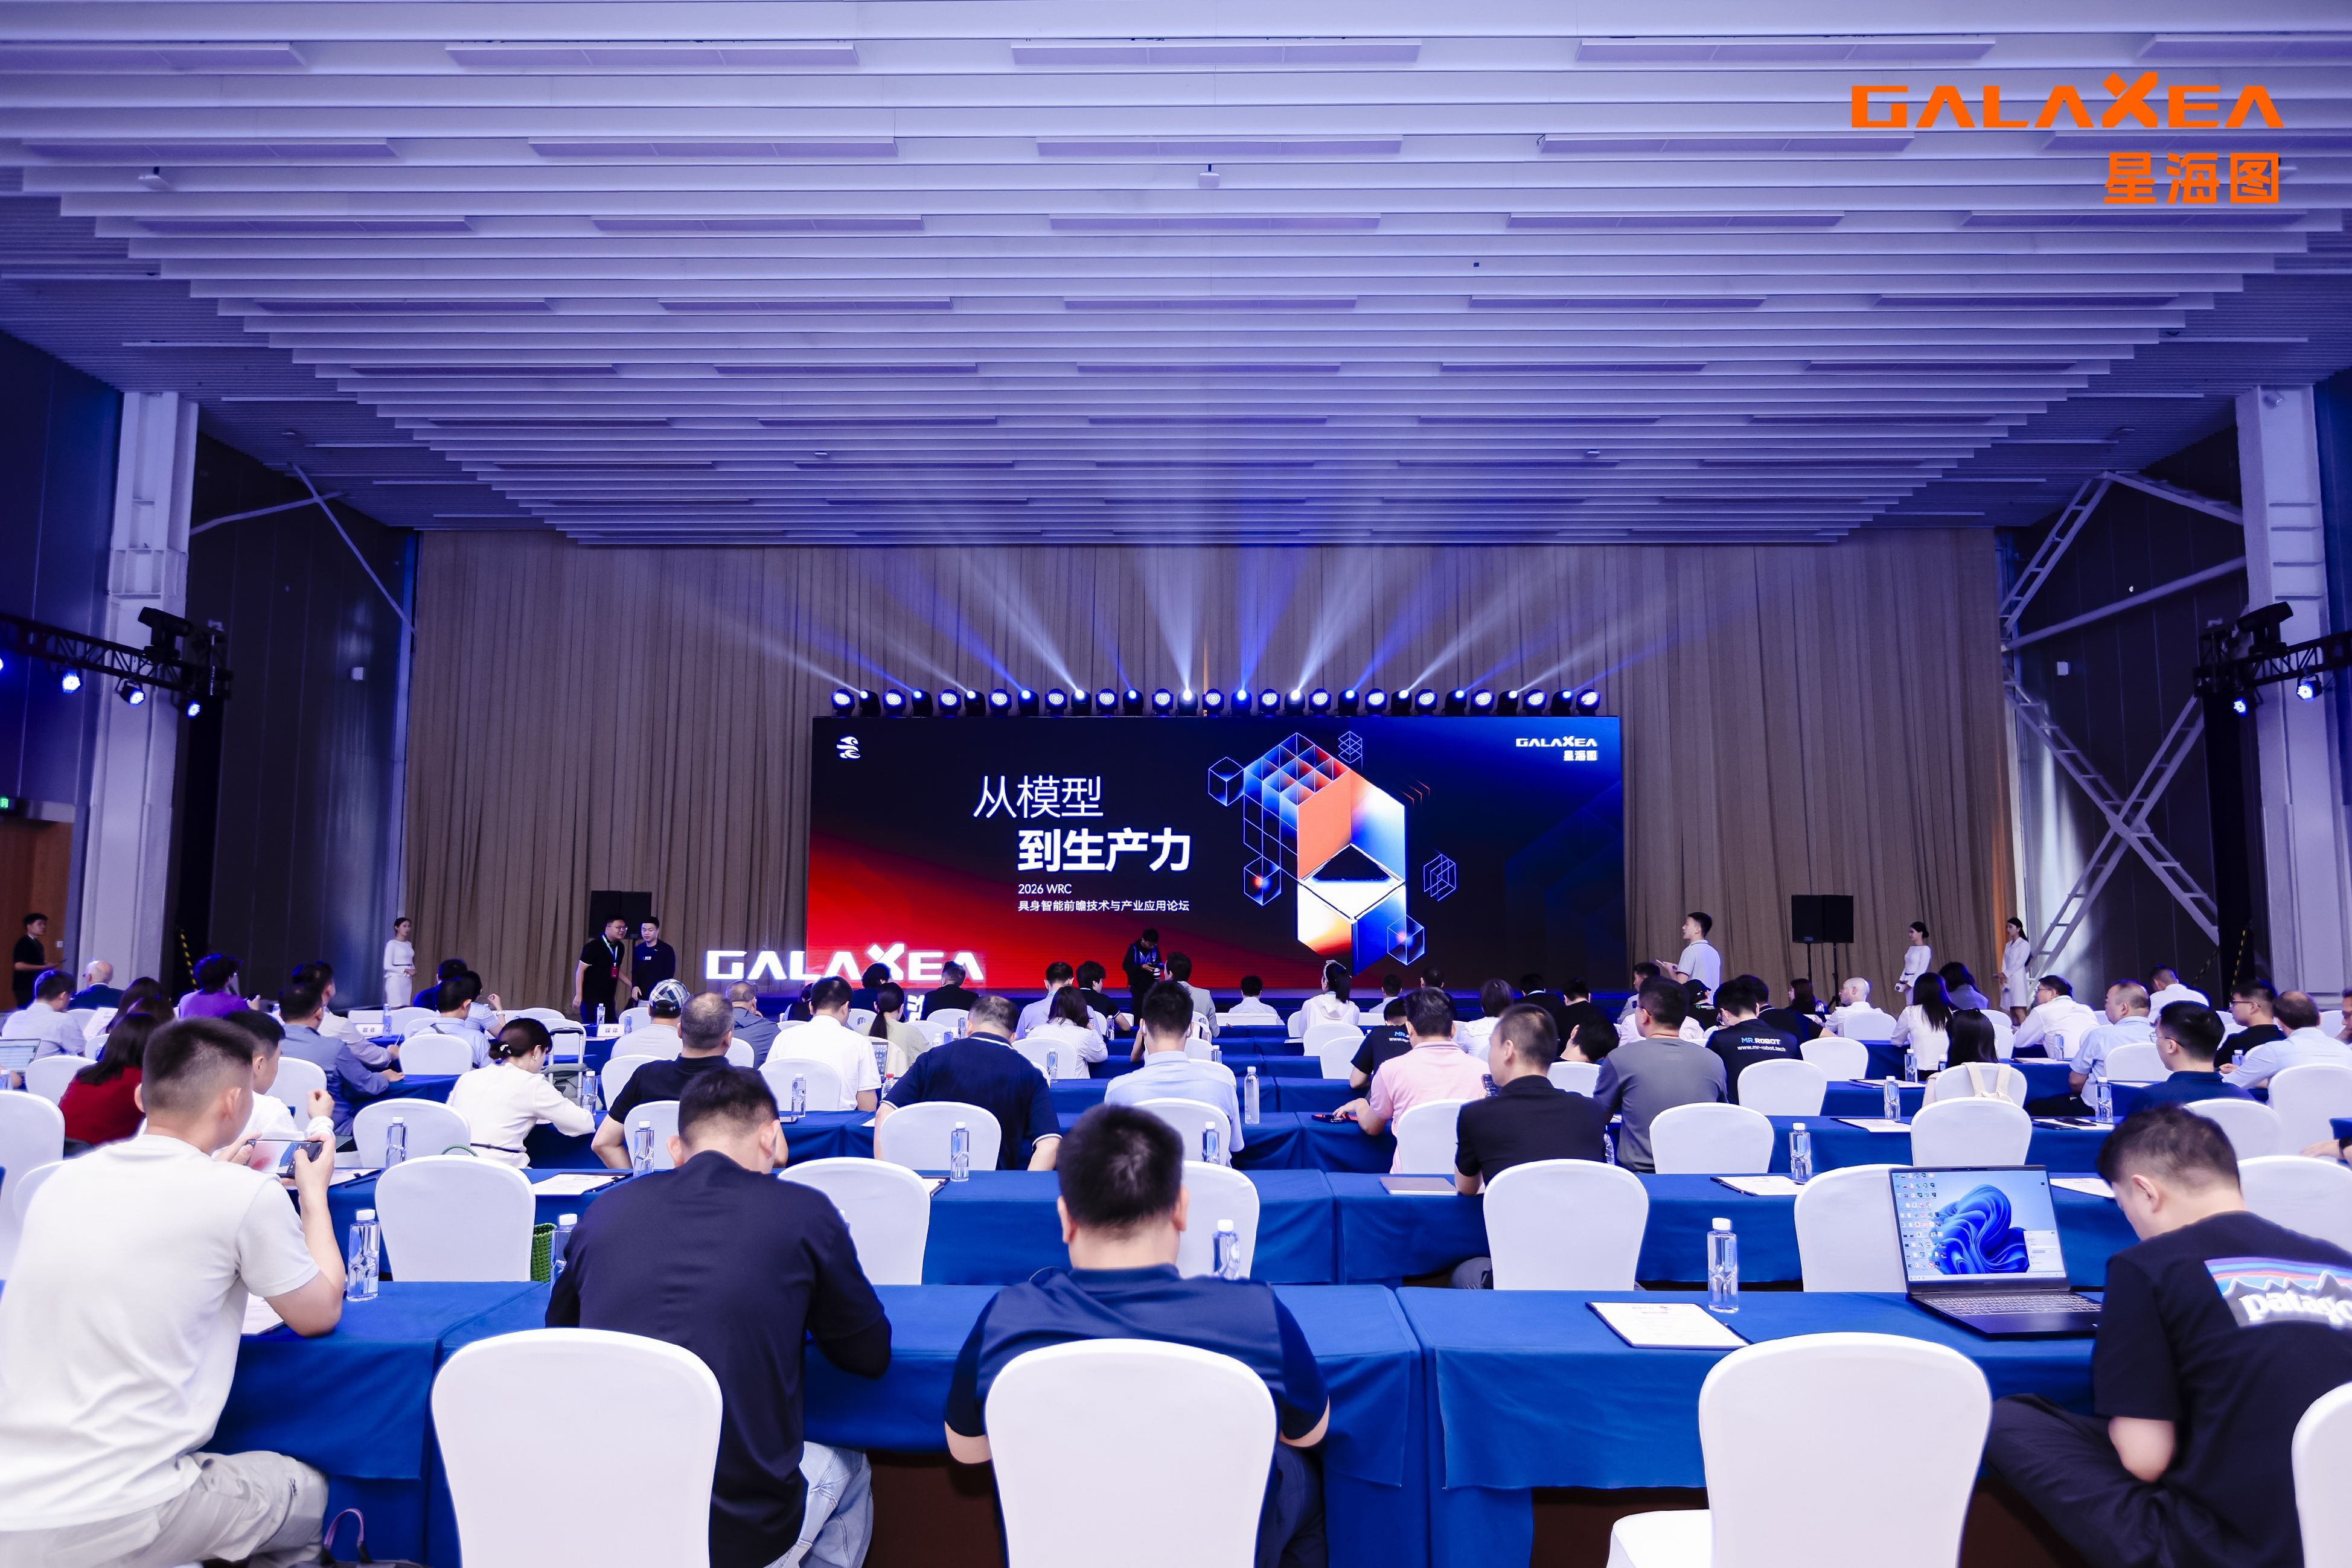
TL;DR - Xinghaitu announced upgrades spanning embodied foundation models, distributed robot learning infrastructure, and three production-oriented robot platforms. The releases target the transition from laboratory prototypes to continuously improving, commercially deployed robotic systems.
- The forthcoming G0.5 MAX builds on G0.5’s unified autoregressive pipeline for visual perception, language, reasoning, and action generation; Xinghaitu also launched a reproduction program providing weights, inference APIs, benchmarks, and fine-tuning tools.
- Fast-WAM avoids generating future video during inference, reportedly reducing single-step latency from roughly 800 ms to 190 ms; a pretrained model based on the architecture is planned.
- The new G-Fleet system supports fleet-wide policy deployment, parallel physical rollouts, human correction, distributed reinforcement learning, evaluation, and model releases in a continuous real-world learning loop.
- Xinghaitu presented the Nexo wheeled dual-arm robot, Kengo biped, and Lemo desktop platform, and reported orders totaling thousands of model-driven robots, with a target of more than 10,000 deliveries next year.