具身大满贯还全开源!原力灵机DM0.5登顶RoboDojo,且clone且珍惜
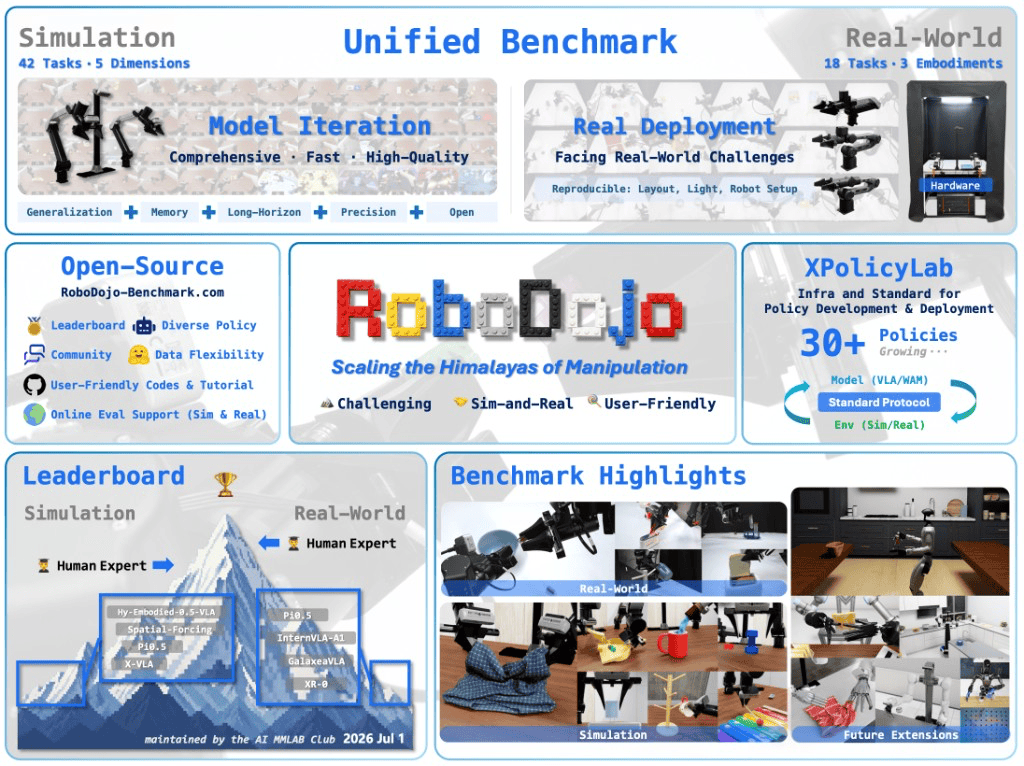
TL;DR - Dexmal’s open-source DM0.5 vision-language-action model topped the RoboDojo embodied-AI benchmark with a 24.90 overall score and 19.34% average success rate. Its strong long-term memory, cross-task generalization, and substantially reduced inference latency support deployment across varied robotic tasks.
- DM0.5 scored 47.74 on RoboDojo’s memory dimension and completed all three randomized Cover Blocks trials, aided by native support for up to 60 seconds of action history.
- The model also reported 99.0% success on LIBERO and strong results on RoboTwin 2.0, VLA-Arena, and RoboChallenge Table30 v2.
- Its architecture combines a 4B-parameter VLM with embodied chain-of-thought tasks, counterfactual instructions, trajectory-alignment supervision, and a System 1/System 2 control hierarchy.
- Optimization reduced core inference latency from 534.04 ms to 57.49 ms—a 9.29× speedup—with LIBERO performance nearly unchanged; model weights, training framework, and downstream workflows are open source.