今年最难的机器人Demo,“机器人含量”为0
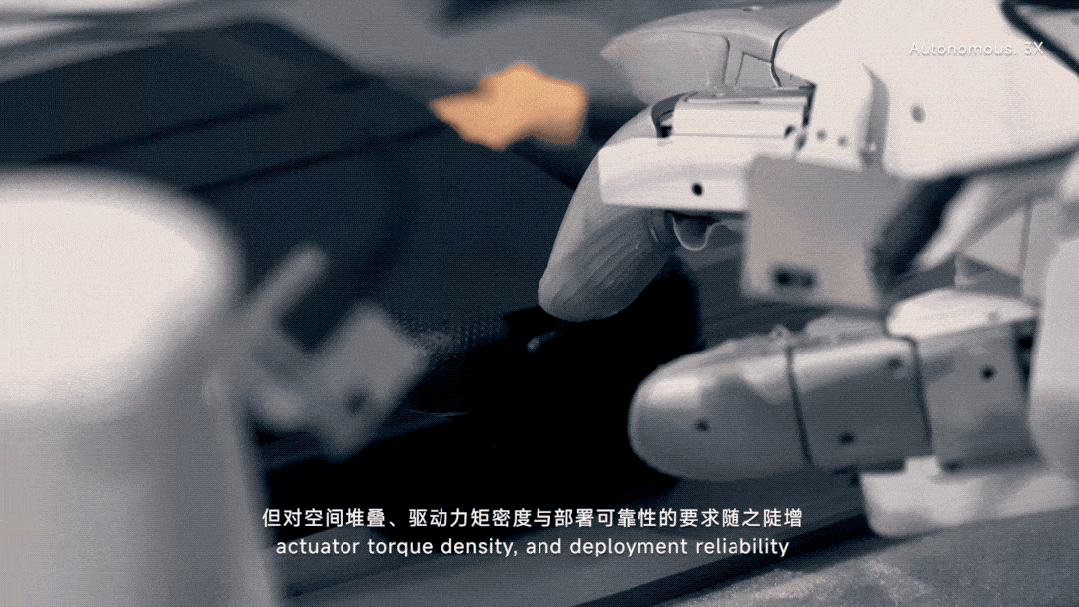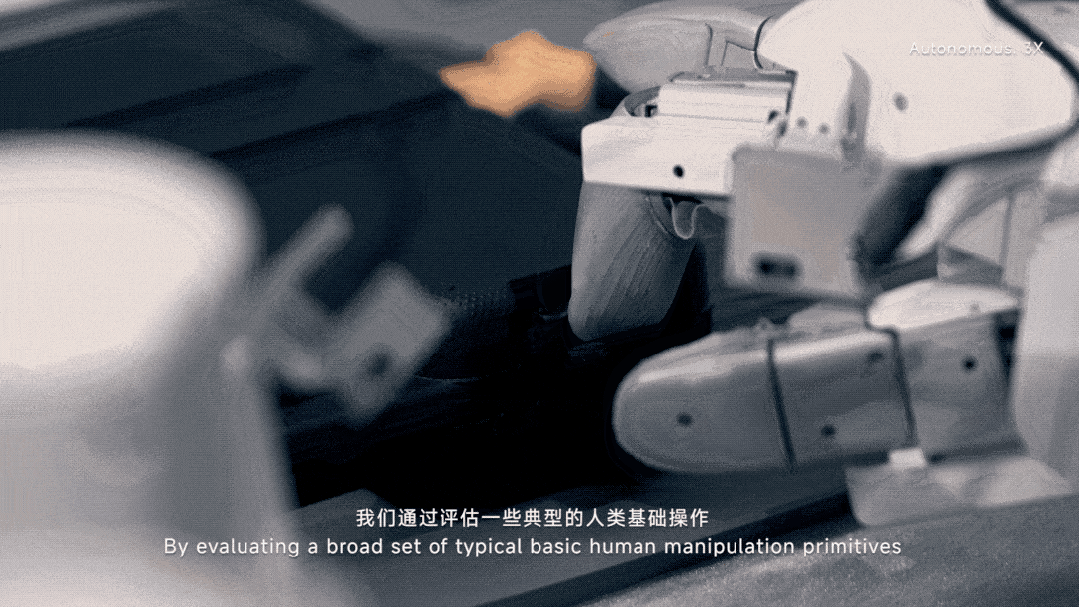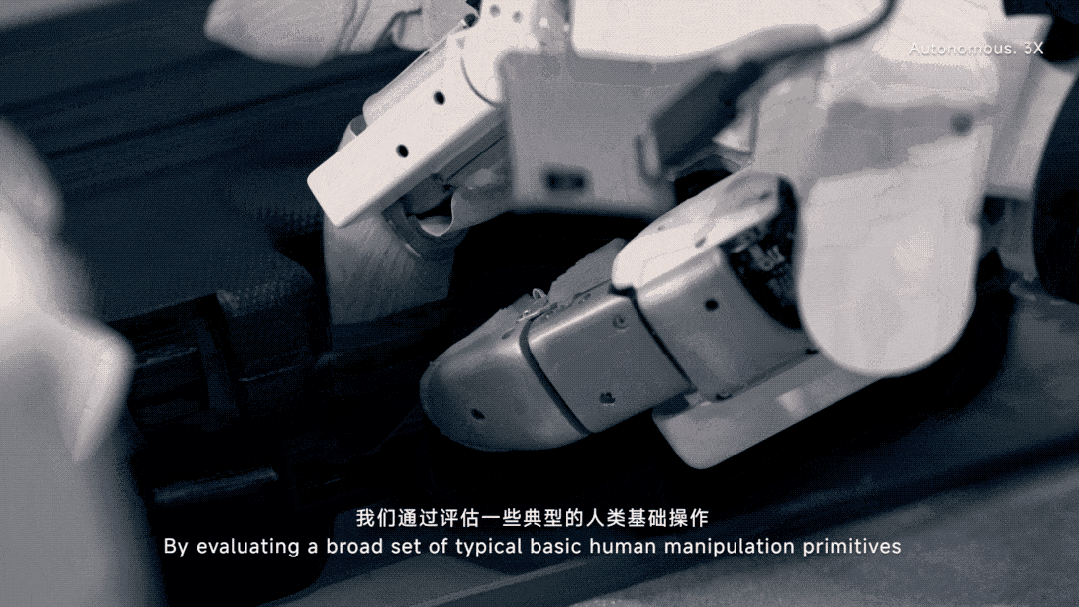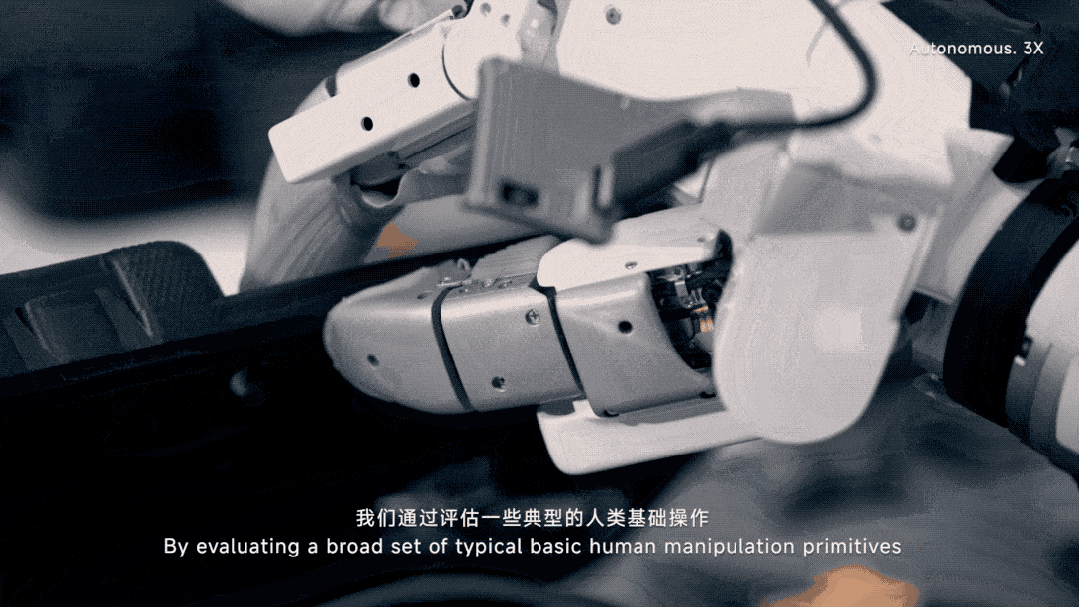
TL;DR - X2 Robot introduced TwinDEX, a three-finger dexterous manipulation system that completed multi-step laboratory tasks without target-robot teleoperation data during post-training. Its matched wearable data collector and robotic end effector could make high-quality embodied-AI data substantially easier to scale.
- TwinDEX performed a 24-step chemistry workflow involving three tools, bimanual coordination, cap twisting, syringe operation, pouring, and other precision actions.
- The system uses an isomorphic three-finger, nine-degree-of-freedom design for both wearable data collection and robot execution, reducing embodiment-transfer errors.
- X2 Robot reports that TwinDEX generated usable trajectories 5.3 times faster than conventional robot teleoperation.
- In the reported tasks, policies trained on a few hundred embodiment-free demonstrations approached the performance and scaling behavior of those trained with robot teleoperation data.