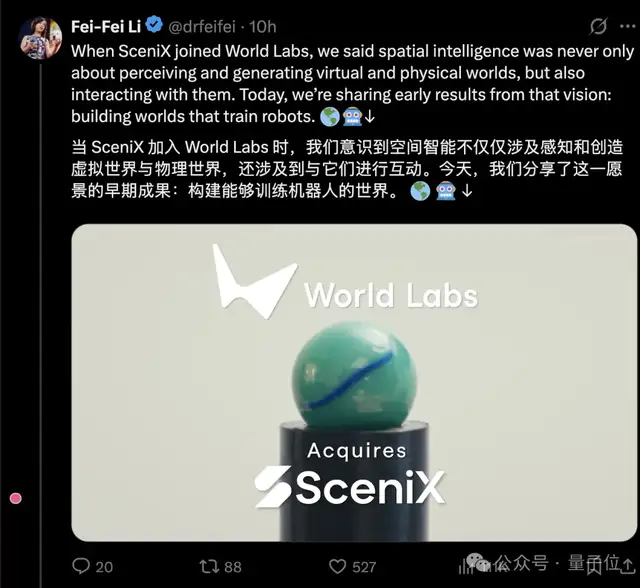
李飞飞World Labs收购SceniX,物理AI训练正从“采数据”走向“造世界”
Ranking
Overall
71
Content
80
Popularity
N/A
No observed public metrics; popularity remains neutral/archived.
Merged summary
TL;DR - World Labs acquired robotics simulation company SceniX to advance real-to-sim-to-real training, signaling a shift from visually generating 3D worlds to simulating the physical consequences of robot actions.
- SceniX adds task reconstruction, physical-property recovery, interaction simulation, and robot policy evaluation to World Labs’ world-model capabilities.
- The R2S2R workflow reconstructs real tasks in simulation, expands them into controlled scenarios, trains and evaluates policies, then deploys them back to physical robots.
- Effective physical-AI infrastructure requires a closed loop spanning real-world data collection, generative scenario expansion, physics simulation, training, evaluation, and real-world feedback.
- The emerging competitive metric is not raw data or asset volume, but how many useful training worlds can be created and whether they measurably improve robot capabilities.
Sources (1)
李飞飞World Labs收购SceniX,物理AI训练正从“采数据”走向“造世界”
Public signals
N/A
TL;DR - World Labs acquired robotics simulation company SceniX to advance real-to-sim-to-real training, signaling a shift from visually generating 3D worlds to simulating the physical consequences of robot actions.
- SceniX adds task reconstruction, physical-property recovery, interaction simulation, and robot policy evaluation to World Labs’ world-model capabilities.
- The R2S2R workflow reconstructs real tasks in simulation, expands them into controlled scenarios, trains and evaluates policies, then deploys them back to physical robots.
- Effective physical-AI infrastructure requires a closed loop spanning real-world data collection, generative scenario expansion, physics simulation, training, evaluation, and real-world feedback.
- The emerging competitive metric is not raw data or asset volume, but how many useful training worlds can be created and whether they measurably improve robot capabilities.