蚂蚁首次投向机器人“指尖”!数亿元押注,全球首个物理交互脑发布
Ranking
No observed public metrics; popularity remains neutral/archived.
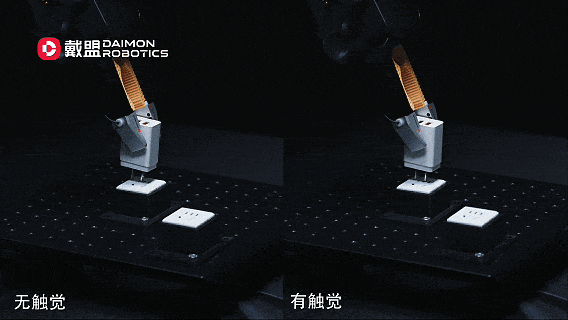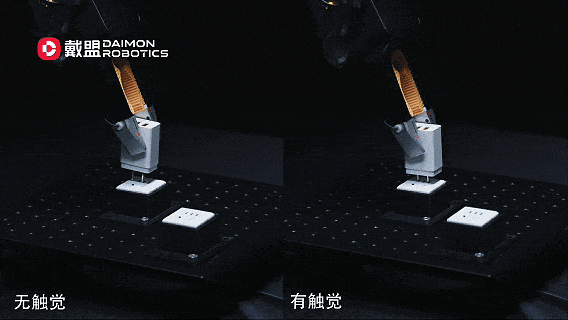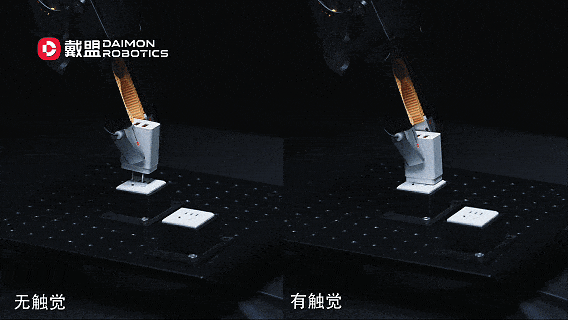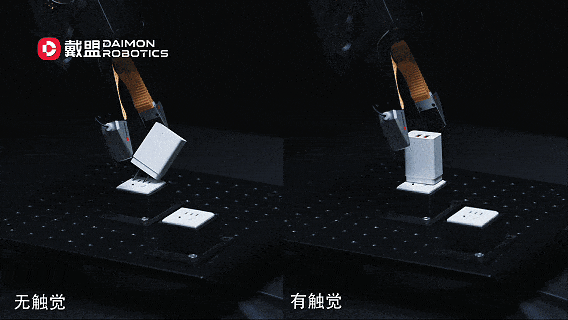
Merged summary
TL;DR — Chinese tactile-robotics startup Daimon Robotics (戴盟) raised a several-hundred-million-RMB strategic round led by Ant Group — Ant's first bet on robot "fingertips" — alongside launching Daimon-TWM, billed as the world's first tactile-grounded world model ("physical interaction brain") for dexterous manipulation. It signals capital rotating from robot bodies to the tactile sensing layer as the bottleneck for embodied AI.
- Daimon-TWM architecture: ~10B params, three cooperating layers — an RL-based physical-cognition module (contact state, force/deformation, material properties), a world-model prediction module for anticipating contact evolution and failure risk, and a 100Hz tactile-feedback servo loop for millisecond corrections. Uses learnable "unified tactile tokens" to build a shared tactile latent space; runs real-time inference on an RTX 5090 with cross-embodiment/cross-arm deployment claims.
- Claimed results: on contact-rich manipulation, ~2× average success rate over π0.5 without disturbance and ~10× under disturbance; demo task is clearing broken glass (reorienting shards vertically to avoid dragging the tablecloth). Positioned as going beyond Fei-Fei Li's T-Rex, which argued tactile is an independent high-frequency channel that can hurt VLAs if naively concatenated.
- Data and ecosystem flywheel: Daimon-Infinity dataset claims the largest tactile-inclusive multimodal manipulation corpus (hundreds of thousands of hours, targeting millions within the year); first 10k open-sourced hours reportedly hit ~5M ModelScope downloads. Also a RobOmni tactile evaluation benchmark, a China Mobile take-home data-collection network, and a "5S store" data depot in Chenzhou targeting 1M hours/year from 1,000 device kits.
- Commercial traction (company-stated): 10k+ visuotactile sensor units shipped, coverage of ~80% of dexterous-hand makers, 200+ customers including OpenAI, Figure, Physical Intelligence, Skild AI, Meta, BMW, and Google DeepMind. Prior backers include China Merchants Capital, Lenovo Capital, Inovance, China Mobile, and China Telecom. Note these are vendor/press claims, not independently verified benchmarks.
Sources (1)
蚂蚁首次投向机器人“指尖”!数亿元押注,全球首个物理交互脑发布
TL;DR — Chinese tactile-robotics startup Daimon Robotics (戴盟) raised a several-hundred-million-RMB strategic round led by Ant Group — Ant's first bet on robot "fingertips" — alongside launching Daimon-TWM, billed as the world's first tactile-grounded world model ("physical interaction brain") for dexterous manipulation. It signals capital rotating from robot bodies to the tactile sensing layer as the bottleneck for embodied AI.
- Daimon-TWM architecture: ~10B params, three cooperating layers — an RL-based physical-cognition module (contact state, force/deformation, material properties), a world-model prediction module for anticipating contact evolution and failure risk, and a 100Hz tactile-feedback servo loop for millisecond corrections. Uses learnable "unified tactile tokens" to build a shared tactile latent space; runs real-time inference on an RTX 5090 with cross-embodiment/cross-arm deployment claims.
- Claimed results: on contact-rich manipulation, ~2× average success rate over π0.5 without disturbance and ~10× under disturbance; demo task is clearing broken glass (reorienting shards vertically to avoid dragging the tablecloth). Positioned as going beyond Fei-Fei Li's T-Rex, which argued tactile is an independent high-frequency channel that can hurt VLAs if naively concatenated.
- Data and ecosystem flywheel: Daimon-Infinity dataset claims the largest tactile-inclusive multimodal manipulation corpus (hundreds of thousands of hours, targeting millions within the year); first 10k open-sourced hours reportedly hit ~5M ModelScope downloads. Also a RobOmni tactile evaluation benchmark, a China Mobile take-home data-collection network, and a "5S store" data depot in Chenzhou targeting 1M hours/year from 1,000 device kits.
- Commercial traction (company-stated): 10k+ visuotactile sensor units shipped, coverage of ~80% of dexterous-hand makers, 200+ customers including OpenAI, Figure, Physical Intelligence, Skild AI, Meta, BMW, and Google DeepMind. Prior backers include China Merchants Capital, Lenovo Capital, Inovance, China Mobile, and China Telecom. Note these are vendor/press claims, not independently verified benchmarks.