攻克行业级柔性操作难题!招商局狮子山人工智能实验室首次亮相WRC 2026
Ranking
No observed public metrics; popularity remains neutral/archived.
Merged summary
TL;DR — 招商局狮子山人工智能实验室在 WRC 2026 首次展示面向行业级柔性物体操作的端云协同基础设施 LiOS,以及可自主折叠、整理复杂衣物的双臂机器人系统,重点突破仿真到现实迁移与系统集成难题。相关报道同时呈现了以模型、灵巧手和人体动作采集构成闭环的具身智能技术路线。
- LiOS 集成分布式模型训练、仿真评测、机器人运行控制、远程干预和真实数据采集,形成持续迭代的数据与执行闭环。
- 实验室称其自研视觉—语言—动作模型及基础设施可将训练吞吐提升 5 倍以上、仿真评测提速 4 倍以上;云端视频链路约 30 毫秒即可将相机数据送入 GPU 显存,兼顾云端推理与实时控制。
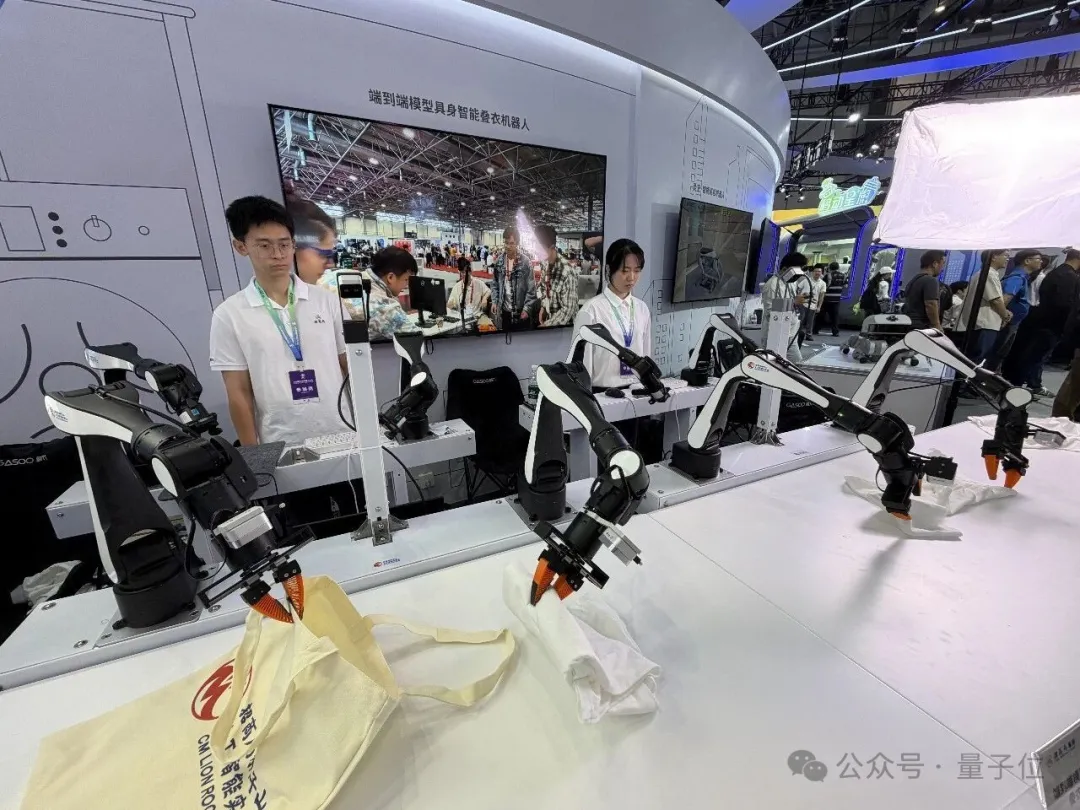
- 双臂系统已适配多种机器人平台,可自主折叠衬衫和长裤,并处理缠结或严重褶皱的衣物;该系统还获得 ICRA 2026 LeHome Challenge 冠军。
- 另一套报道中的“脑—手—数据”闭环包括可控世界模型与世界—动作模型 SYNWorld、多指协调和柔顺力控的 OctoH-Hand,以及融合头部、肌电和手套数据的 OctoSense,用于物理推理、策略生成、跨任务迁移和真实反馈学习。
- SynapX 称其肌电采集方案可跨个体零样本泛化,并提高人类示范动作与机器人执行动作的一致性。
注: 两个来源强调的主体和系统并不一致:量子位聚焦招商局狮子山实验室的 LiOS 与衣物折叠系统,雷峰网则报道 SynapX 的“脑—手—数据”技术栈;现有信息不足以确认两者属于同一项目。
Sources (2)
攻克行业级柔性操作难题!招商局狮子山人工智能实验室首次亮相WRC 2026
TL;DR - China Merchants Group’s Lion Rock AI Lab debuted its LiOS edge-cloud infrastructure and autonomous dual-arm clothing-folding system at WRC 2026. The system targets the sim-to-real and systems-integration barriers that make deformable-object manipulation difficult to deploy on real robots.
- LiOS unifies distributed model training, simulation evaluation, robot runtime control, remote intervention, and real-world data collection into a closed-loop infrastructure.
- The lab reports over 5× higher training throughput and over 4× faster simulation evaluation, supported by an in-house vision-language-action model.
- Its cloud video pipeline reportedly delivers camera data to GPU memory in roughly 30 ms, enabling cloud inference while preserving real-time robot execution.
- Demonstrations covered multiple dual-arm platforms, autonomous folding of shirts and trousers, and recovery of tangled or heavily wrinkled garments; the system also won the ICRA 2026 LeHome Challenge.
章鱼动力亮相WRC 2026, 携“脑-手-数据”技术体系探索具身智能未来范式
TL;DR - SynapX unveiled an integrated “brain-hand-data” robotics stack at WRC 2026, combining a world foundation model, a dexterous robotic hand, and human-motion data-capture hardware. The company positions this closed-loop system as infrastructure for robots that can generalize and continually improve in real-world tasks.
- SYNWorld combines an action-controllable world model and a world-action model to support physical reasoning, decision-making, and cross-task or cross-robot transfer.
- OctoH-Hand provides high-degree-of-freedom manipulation with multi-finger coordination, multimodal sensing, compliant force control, and precision grasping.
- OctoSense uses head-, muscle-, and glove-based capture hardware; SynapX claims its electromyography approach enables zero-shot generalization across individuals and close alignment between human demonstrations and robot actions.
- The three components form a proposed loop of data collection, world understanding, policy generation, and real-world feedback.