机器人首秀网球场,银河通用突破具身智能「AstraTennis时刻」
Ranking
Overall
61
Content
65
Popularity
N/A
No observed public metrics; popularity remains neutral/archived.
Merged summary
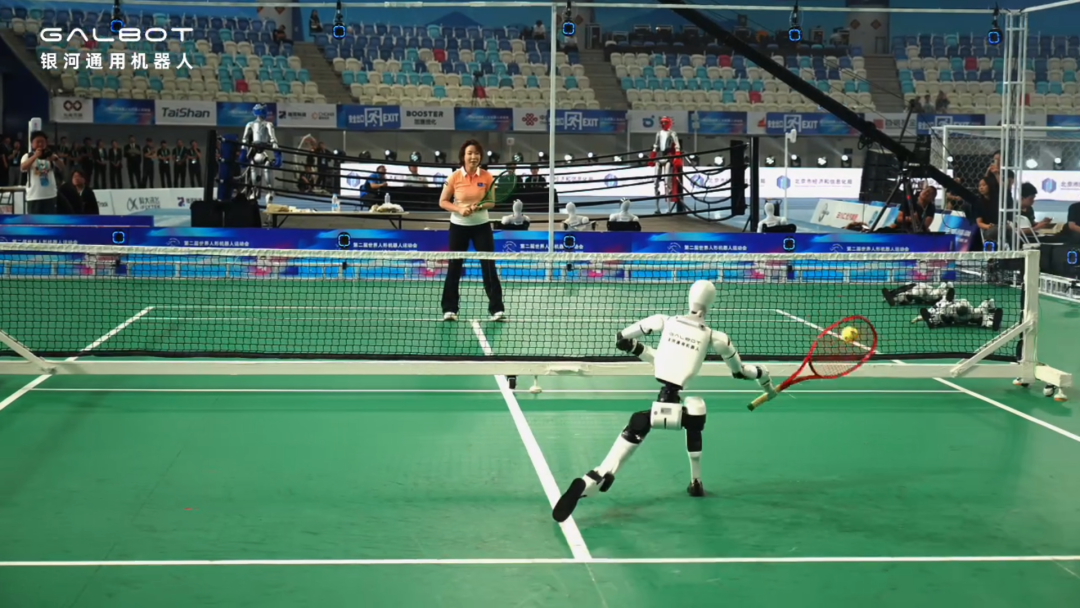
TL;DR - Galbot demonstrated AstraTennis, described as the first fully autonomous humanoid robot to sustain real-time tennis rallies. The showcase matters because it integrates high-level decision-making, whole-body control, and simulation-based training in a fast, unpredictable physical task.
- AstraBrain unifies tactical reasoning, motion control, and translation of decisions into whole-body actions within a real-time closed loop.
- AstraBrain Latent extracts reusable motion skills from fragmented, non-expert human demonstrations rather than relying on costly, complete teleoperation data.
- The robot trains through multi-agent self-play in a simulated tennis environment built on the company’s large-scale embodied-AI dataset, followed by limited real-world calibration.
- During live play, it handled serves, forehands, backhands, positioning, doubles coordination, and autonomous recovery after a fall.
Sources (1)
机器人首秀网球场,银河通用突破具身智能「AstraTennis时刻」
Public signals
N/A
TL;DR - Galbot demonstrated AstraTennis, described as the first fully autonomous humanoid robot to sustain real-time tennis rallies. The showcase matters because it integrates high-level decision-making, whole-body control, and simulation-based training in a fast, unpredictable physical task.
- AstraBrain unifies tactical reasoning, motion control, and translation of decisions into whole-body actions within a real-time closed loop.
- AstraBrain Latent extracts reusable motion skills from fragmented, non-expert human demonstrations rather than relying on costly, complete teleoperation data.
- The robot trains through multi-agent self-play in a simulated tennis environment built on the company’s large-scale embodied-AI dataset, followed by limited real-world calibration.
- During live play, it handled serves, forehands, backhands, positioning, doubles coordination, and autonomous recovery after a fall.