全球首次!机器人迎战网球运动员,极限救球,摔倒光速弹起
Ranking
Overall
61
Content
65
Popularity
N/A
No observed public metrics; popularity remains neutral/archived.
Merged summary
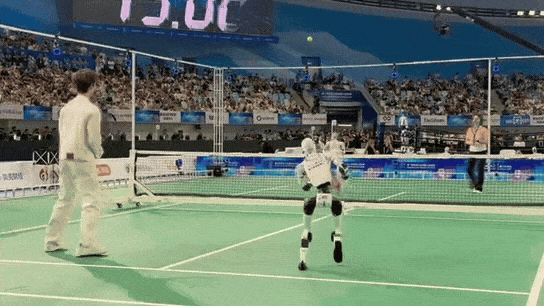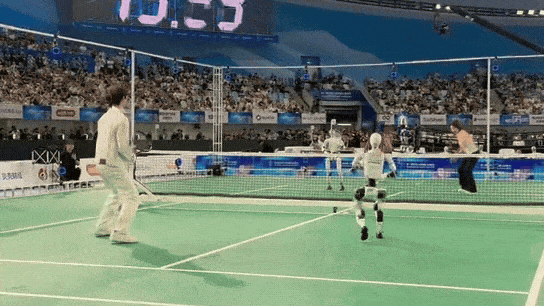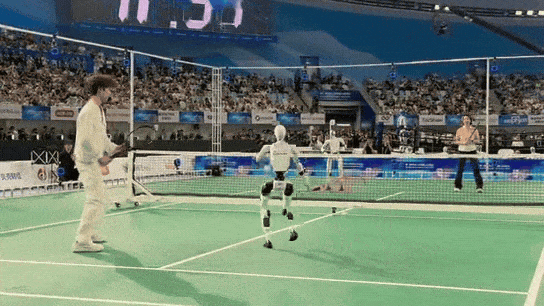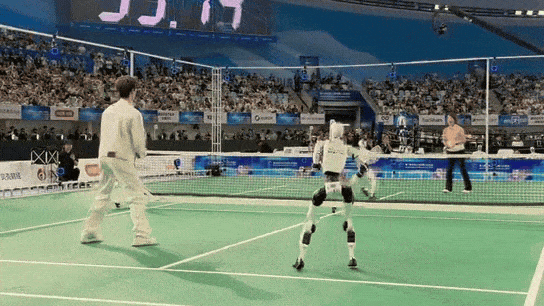
TL;DR - Galbot demonstrated its AstraTennis humanoid autonomously playing tennis against and alongside human athletes in a live event. The showcase matters as a real-world test of closed-loop perception, strategy, whole-body control, and human-robot coordination under fast, unpredictable conditions.
- The robot demonstrated serving, forehands, backhands, volleys, court movement, multi-shot rallies, doubles coordination, and autonomous recovery after falls.
- Galbot says its AstraBrain model unifies high-level decision-making, whole-body motion control, and low-level neural control.
- Training combines imperfect human demonstrations, synthetic data, simulated practice, and multi-agent self-play before transferring learned skills to the physical robot.
- The event was a company-backed demonstration rather than a formal benchmark; the article provides no quantitative comparisons or independently verified performance metrics.
Sources (1)
全球首次!机器人迎战网球运动员,极限救球,摔倒光速弹起
Public signals
N/A
TL;DR - Galbot demonstrated its AstraTennis humanoid autonomously playing tennis against and alongside human athletes in a live event. The showcase matters as a real-world test of closed-loop perception, strategy, whole-body control, and human-robot coordination under fast, unpredictable conditions.
- The robot demonstrated serving, forehands, backhands, volleys, court movement, multi-shot rallies, doubles coordination, and autonomous recovery after falls.
- Galbot says its AstraBrain model unifies high-level decision-making, whole-body motion control, and low-level neural control.
- Training combines imperfect human demonstrations, synthetic data, simulated practice, and multi-agent self-play before transferring learned skills to the physical robot.
- The event was a company-backed demonstration rather than a formal benchmark; the article provides no quantitative comparisons or independently verified performance metrics.