不做硅谷follower:几个读博的年轻人,押注双足人形的一体化大脑
Ranking
No observed public metrics; popularity remains neutral/archived.
Merged summary
TL;DR - Chinese startup Symbiotic Intelligence is developing an end-to-end foundation model that directly controls bipedal humanoids from perception through joint-level action. Its bet matters because unified control could reduce the information bottlenecks of modular robot stacks, although the approach and the broader humanoid-model field remain unproven at commercial scale.
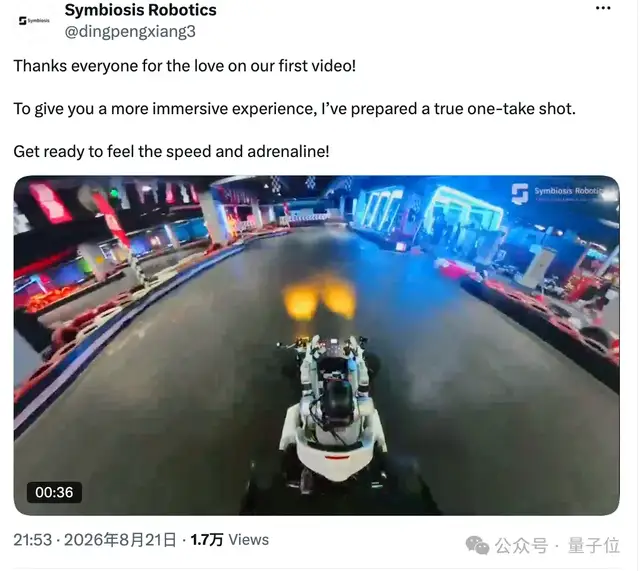
- The two-month-old company demonstrated a humanoid autonomously driving a go-kart using coordinated vision, hands, feet, balance, and force control.
- Its architecture replaces separate high-level planning and low-level control modules with one model that learns whole-body dynamics and outputs joint targets directly.
- A dual-domain training method combines behavior cloning with DriftDistill, which transfers stability, disturbance resistance, and failure-recovery capabilities from specialized controllers into the unified model.
- The team uses TrajBooster to convert trajectories from robot arms and wheeled robots into simulated whole-body training data, but estimates that commercially meaningful capabilities may require roughly one million hours of data.
Sources (1)
不做硅谷follower:几个读博的年轻人,押注双足人形的一体化大脑
TL;DR - Chinese startup Symbiotic Intelligence is developing an end-to-end foundation model that directly controls bipedal humanoids from perception through joint-level action. Its bet matters because unified control could reduce the information bottlenecks of modular robot stacks, although the approach and the broader humanoid-model field remain unproven at commercial scale.
- The two-month-old company demonstrated a humanoid autonomously driving a go-kart using coordinated vision, hands, feet, balance, and force control.
- Its architecture replaces separate high-level planning and low-level control modules with one model that learns whole-body dynamics and outputs joint targets directly.
- A dual-domain training method combines behavior cloning with DriftDistill, which transfers stability, disturbance resistance, and failure-recovery capabilities from specialized controllers into the unified model.
- The team uses TrajBooster to convert trajectories from robot arms and wheeled robots into simulated whole-body training data, but estimates that commercially meaningful capabilities may require roughly one million hours of data.