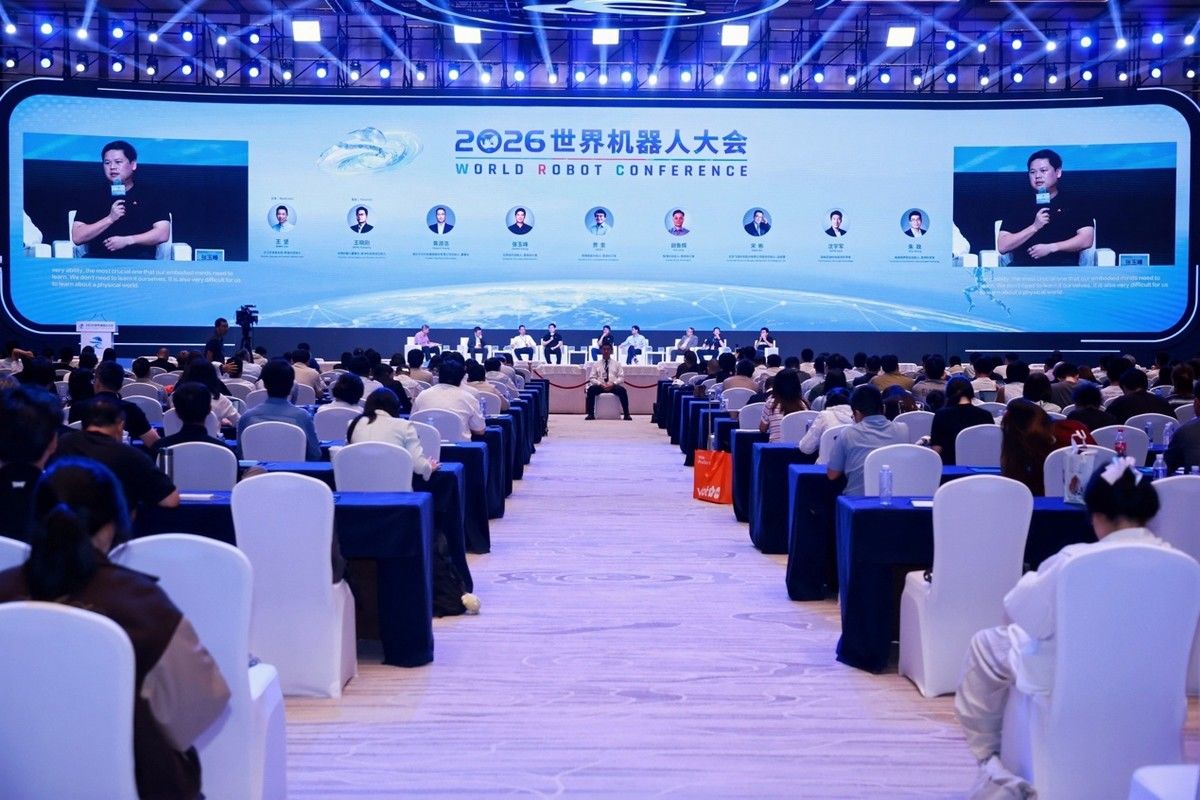
从世界模型到现实生产力,无界动力深度参与WRC主论坛及多场同期活动
Ranking
No observed public metrics; popularity remains neutral/archived.
Merged summary
TL;DR - At the 2026 World Robot Conference, Wujie Dynamics presented its MWA embodied intelligence system and a “latent-space world model + reinforcement learning” approach for moving robots from demonstrations into industrial and commercial deployment. The company argues that real-world deployments should create data feedback loops that improve generalization and reduce adaptation costs.
- MWA models decision-relevant physical representations and causal relationships in latent space rather than attempting pixel-level reconstruction of the environment.
- Reinforcement learning adds trial-and-error feedback so robots can evaluate how actions affect the world and select higher-value behaviors.
- The company uses industrial tasks to develop manipulation skills and variable commercial environments to test generalization under changing layouts, lighting, and human activity.
- Its deployment strategy emphasizes safety redundancy, hardware-software integration, production-grade reliability, and continuous model improvement from operational data.
Sources (1)
从世界模型到现实生产力,无界动力深度参与WRC主论坛及多场同期活动
TL;DR - At the 2026 World Robot Conference, Wujie Dynamics presented its MWA embodied intelligence system and a “latent-space world model + reinforcement learning” approach for moving robots from demonstrations into industrial and commercial deployment. The company argues that real-world deployments should create data feedback loops that improve generalization and reduce adaptation costs.
- MWA models decision-relevant physical representations and causal relationships in latent space rather than attempting pixel-level reconstruction of the environment.
- Reinforcement learning adds trial-and-error feedback so robots can evaluate how actions affect the world and select higher-value behaviors.
- The company uses industrial tasks to develop manipulation skills and variable commercial environments to test generalization under changing layouts, lighting, and human activity.
- Its deployment strategy emphasizes safety redundancy, hardware-software integration, production-grade reliability, and continuous model improvement from operational data.