宇树智元共用一个大脑!神秘模型Demo炸场,10分钟一镜到底
Ranking
No observed public metrics; popularity remains neutral/archived.
Merged summary
TL;DR - QbitAI reports an unedited 10-minute demo in which one unidentified embodied-AI model controls Unitree and AgiBot robots performing household tasks collaboratively. If independently verified, the cross-robot control, long-horizon task recovery, and physical adaptation would represent notable progress beyond hardware-specific VLA systems.
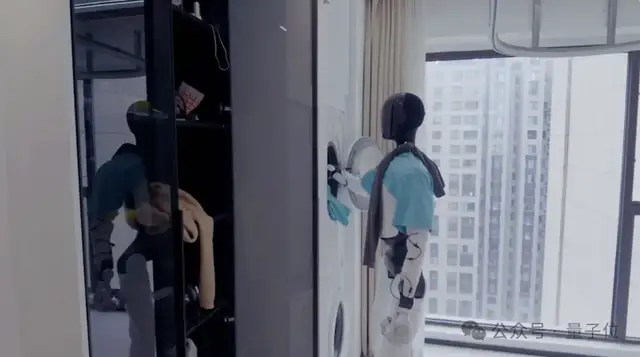
- The robots reportedly navigate a cramped room, manipulate varied objects, clean, organize laundry, and resume interrupted tasks without external commands.
- A shared model allegedly supports different robot bodies through unified action representations and embodiment adaptation, enabling cross-platform collaboration.
- Demonstrated behaviors include force-sensitive manipulation, dynamic task scheduling, repeated action refinement, and using a box to address a height limitation.
- The article attributes these capabilities to physics-constrained dynamics learning and robust closed-loop planning, but the model’s developer, architecture, training details, and independent validation remain undisclosed.
Sources (1)
宇树智元共用一个大脑!神秘模型Demo炸场,10分钟一镜到底
TL;DR - QbitAI reports an unedited 10-minute demo in which one unidentified embodied-AI model controls Unitree and AgiBot robots performing household tasks collaboratively. If independently verified, the cross-robot control, long-horizon task recovery, and physical adaptation would represent notable progress beyond hardware-specific VLA systems.
- The robots reportedly navigate a cramped room, manipulate varied objects, clean, organize laundry, and resume interrupted tasks without external commands.
- A shared model allegedly supports different robot bodies through unified action representations and embodiment adaptation, enabling cross-platform collaboration.
- Demonstrated behaviors include force-sensitive manipulation, dynamic task scheduling, repeated action refinement, and using a box to address a height limitation.
- The article attributes these capabilities to physics-constrained dynamics learning and robust closed-loop planning, but the model’s developer, architecture, training details, and independent validation remain undisclosed.