高德发布首个无长程依赖的万帧级流式3D重建模型ABot-Recon,以12帧重建万帧3D场景
Ranking
No observed public metrics; popularity remains neutral/archived.
Merged summary
TL;DR - Amap released ABot-Recon, an open-source streaming 3D reconstruction model that uses only the latest 12 monocular RGB frames to reconstruct sequences exceeding 10,000 frames in real time. Its fixed local context avoids the growing memory and compute costs of long-term memory while reporting state-of-the-art accuracy on several benchmarks.
- ABot-Recon predicts local point clouds and relative camera poses, then incrementally composes them into a global trajectory and 3D scene.
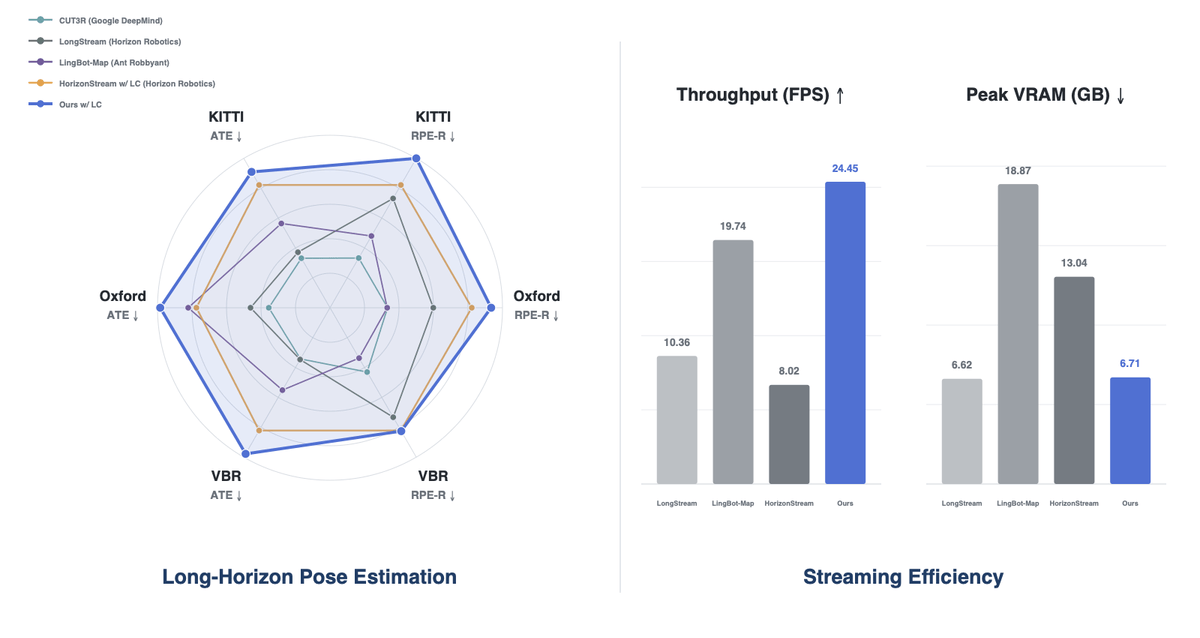
- On Oxford Spires, it reduced average trajectory error by 40.6% versus LingBot-Map and achieved a 0.12° relative rotation error.
- On KITTI-02, it reached 24.45 FPS while peak GPU memory usage was approximately 6.71 GB.
- It requires neither depth sensors nor known camera parameters; inference code, evaluation code, and model weights are available on GitHub.
Sources (1)
高德发布首个无长程依赖的万帧级流式3D重建模型ABot-Recon,以12帧重建万帧3D场景
TL;DR - Amap released ABot-Recon, an open-source streaming 3D reconstruction model that uses only the latest 12 monocular RGB frames to reconstruct sequences exceeding 10,000 frames in real time. Its fixed local context avoids the growing memory and compute costs of long-term memory while reporting state-of-the-art accuracy on several benchmarks.
- ABot-Recon predicts local point clouds and relative camera poses, then incrementally composes them into a global trajectory and 3D scene.
- On Oxford Spires, it reduced average trajectory error by 40.6% versus LingBot-Map and achieved a 0.12° relative rotation error.
- On KITTI-02, it reached 24.45 FPS while peak GPU memory usage was approximately 6.71 GB.
- It requires neither depth sensors nor known camera parameters; inference code, evaluation code, and model weights are available on GitHub.